The first time an AI copilot helps you debug a robot, the limiting factor is usually not the model.
It is the data you give it.
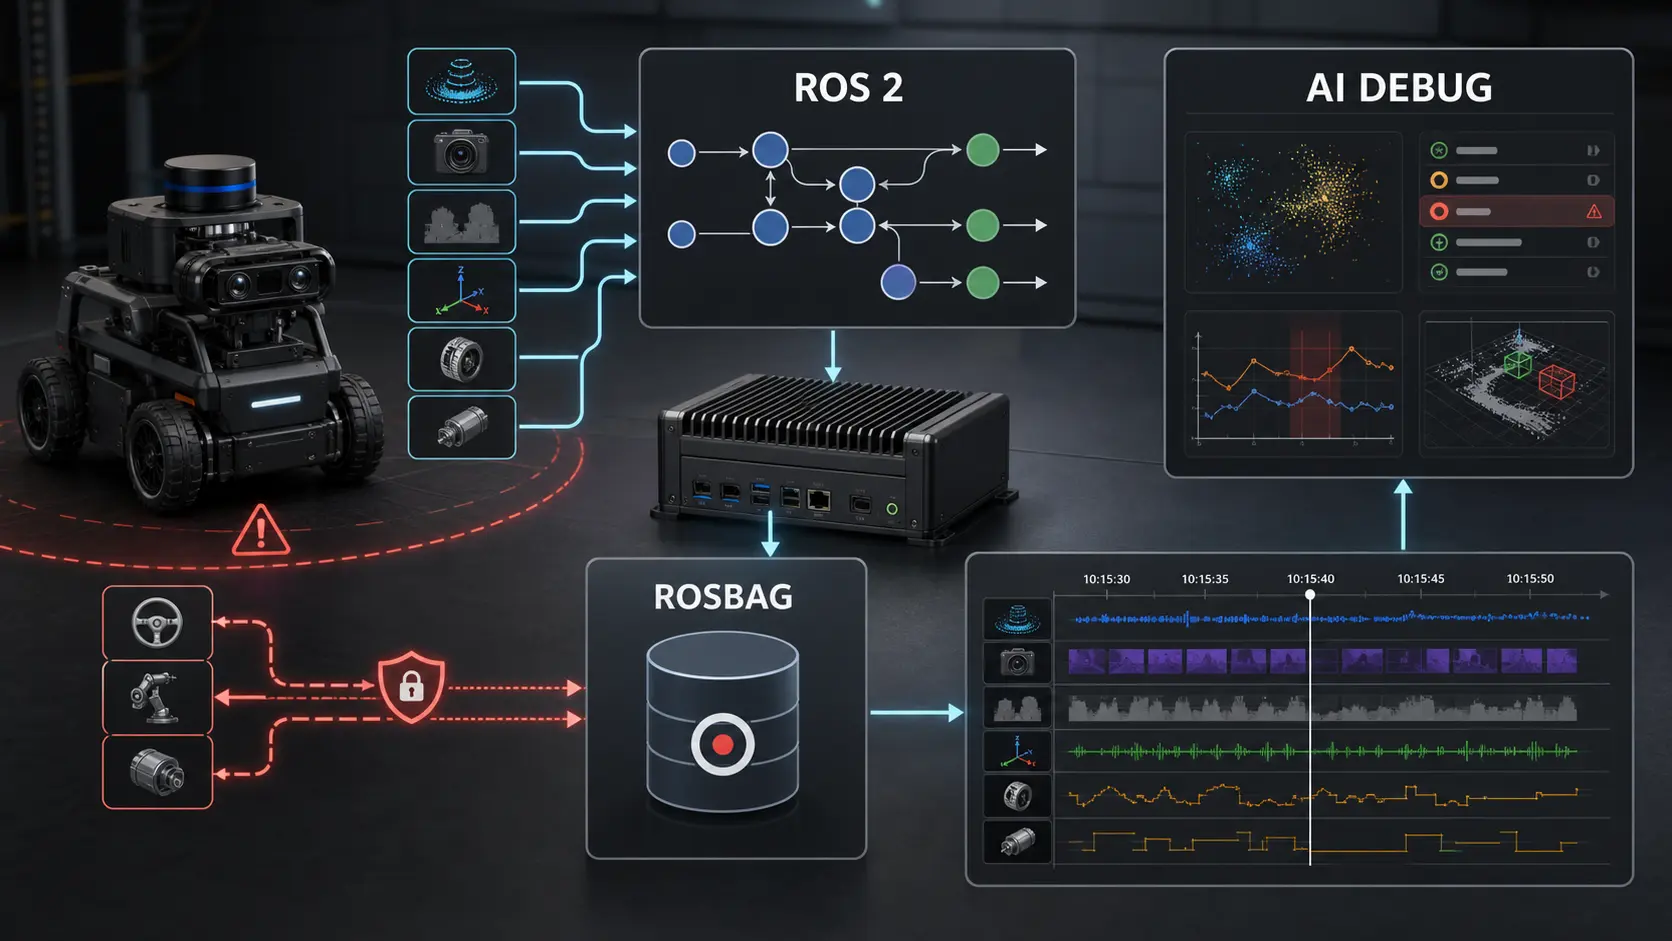
A language model can summarize logs, compare events, inspect a rosbag, spot suspicious timing gaps, and propose hypotheses. But it cannot reconstruct a physical failure from vague console output, missing timestamps, unrecorded commands, stale transforms, dropped sensor frames, or a bag that captured camera images but not the safety state that rejected the motion.